
Blog
DJI L2 vs DJI L1: Comparison Dataset and Accuracy Reports

05
Dec
Dec
In-depth comparison between the new DJI Zenmuse L2 and its predecessor, DJI Zenmuse L1. View example datasets showing L2’s improved capabilities, including its ability to better capture finer details, such as power lines, and create denser DTMs.
The DJI Zenmuse L2 offers greater precision, greater efficiency and creates more robust point clouds than its predecessor, the L1.
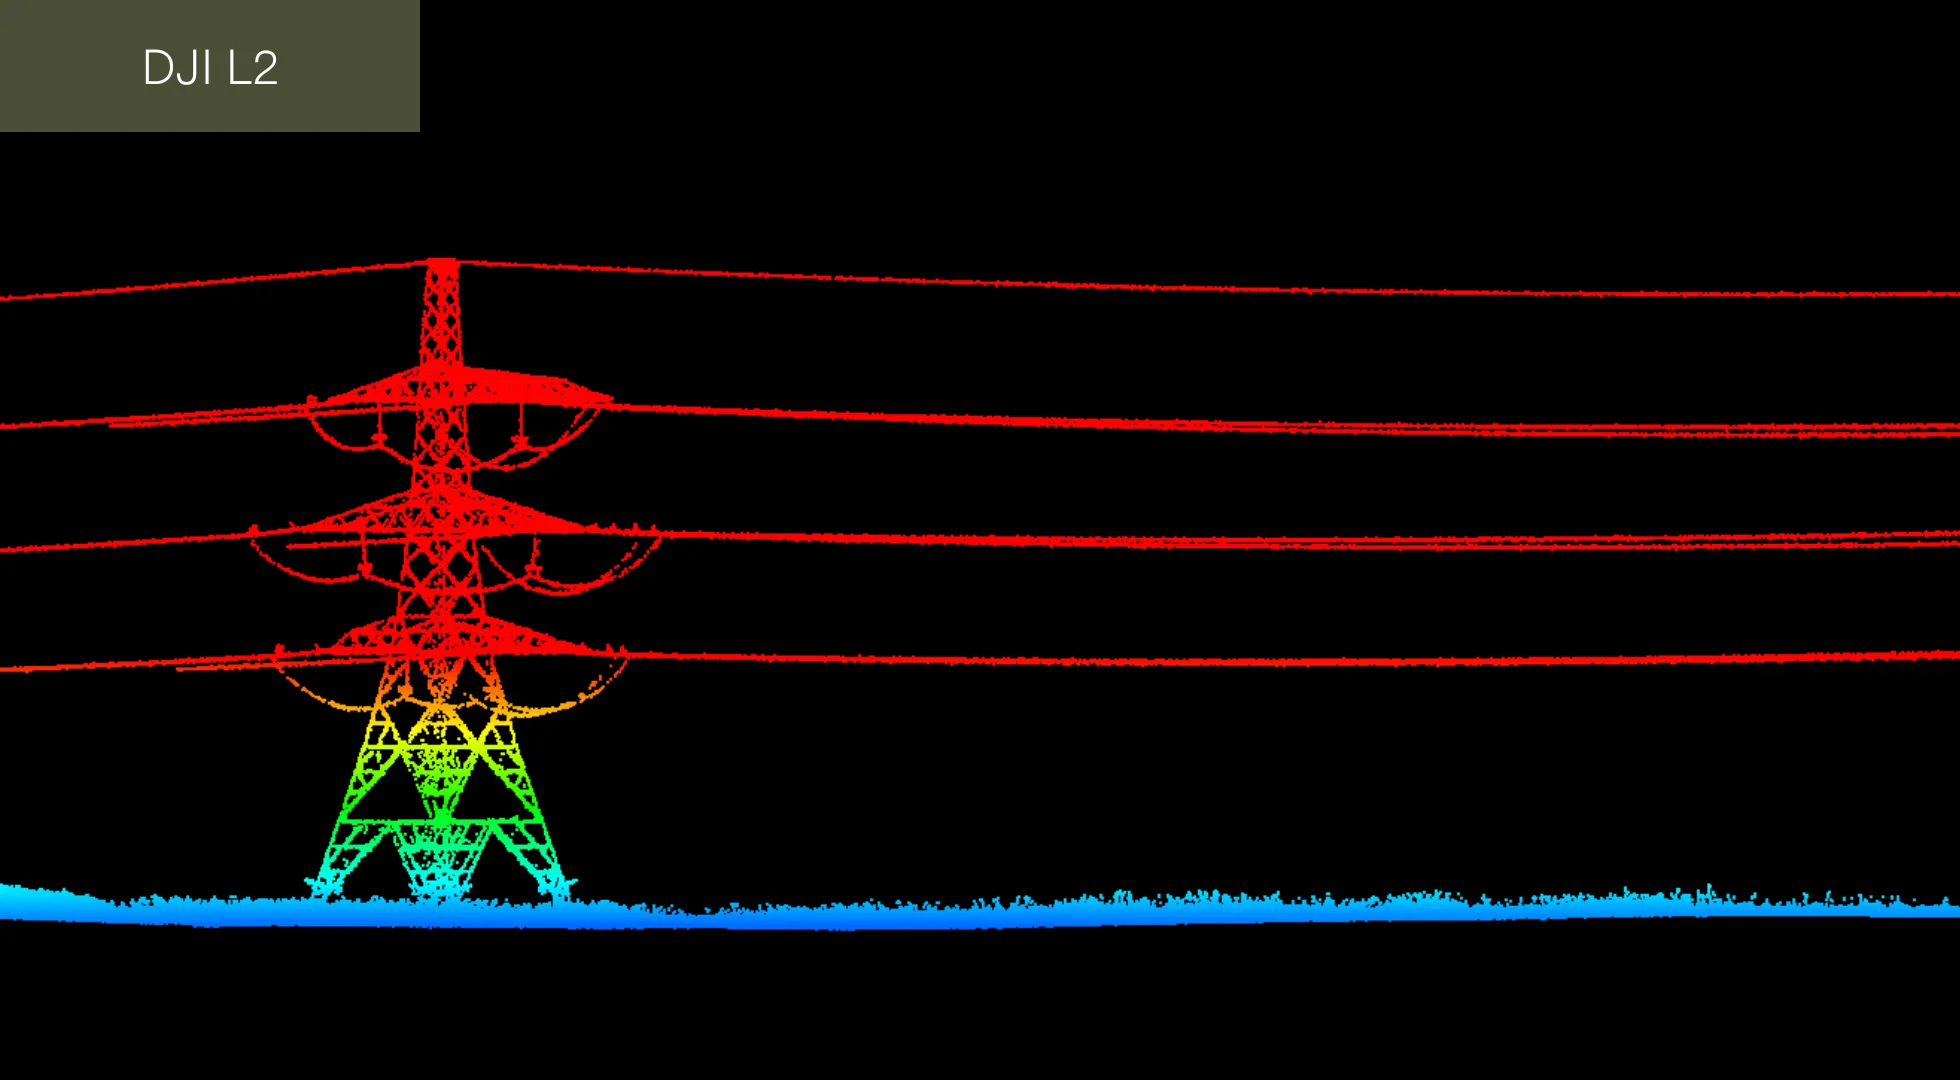
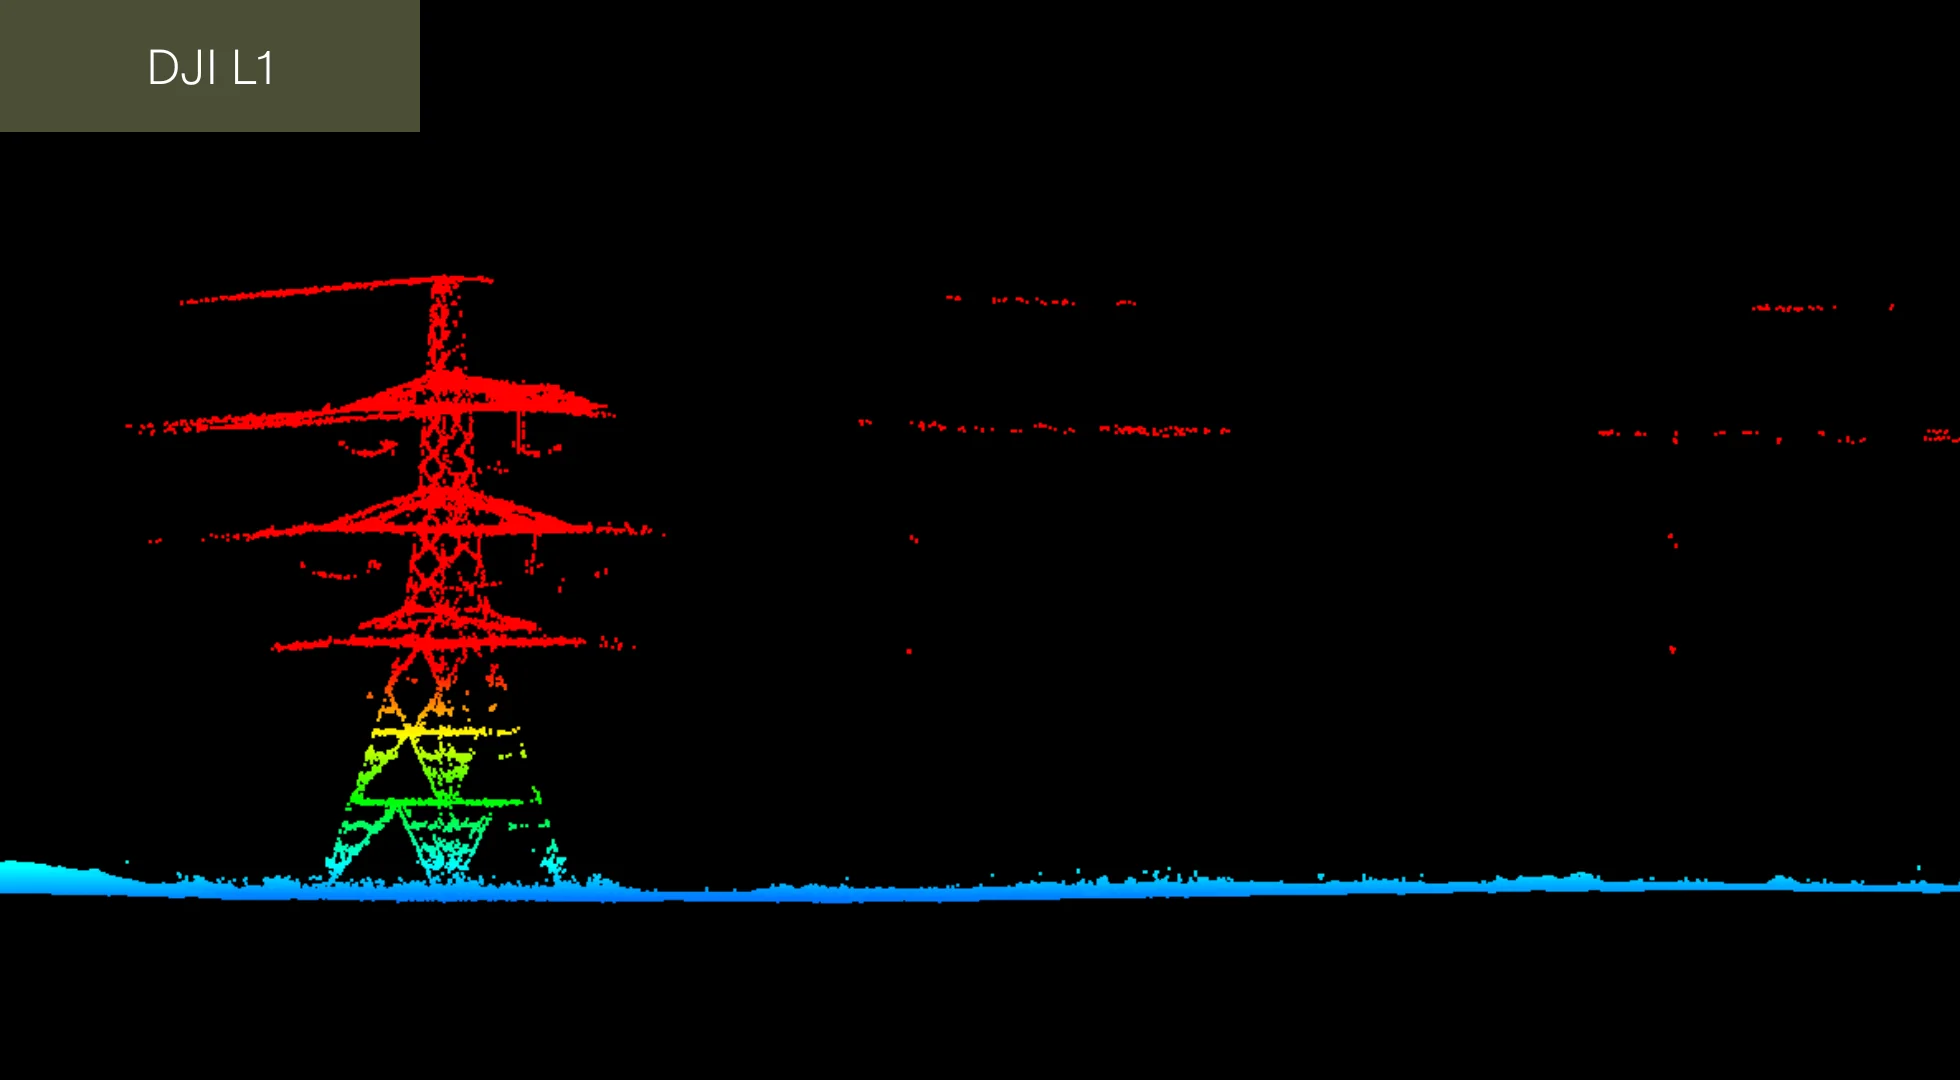
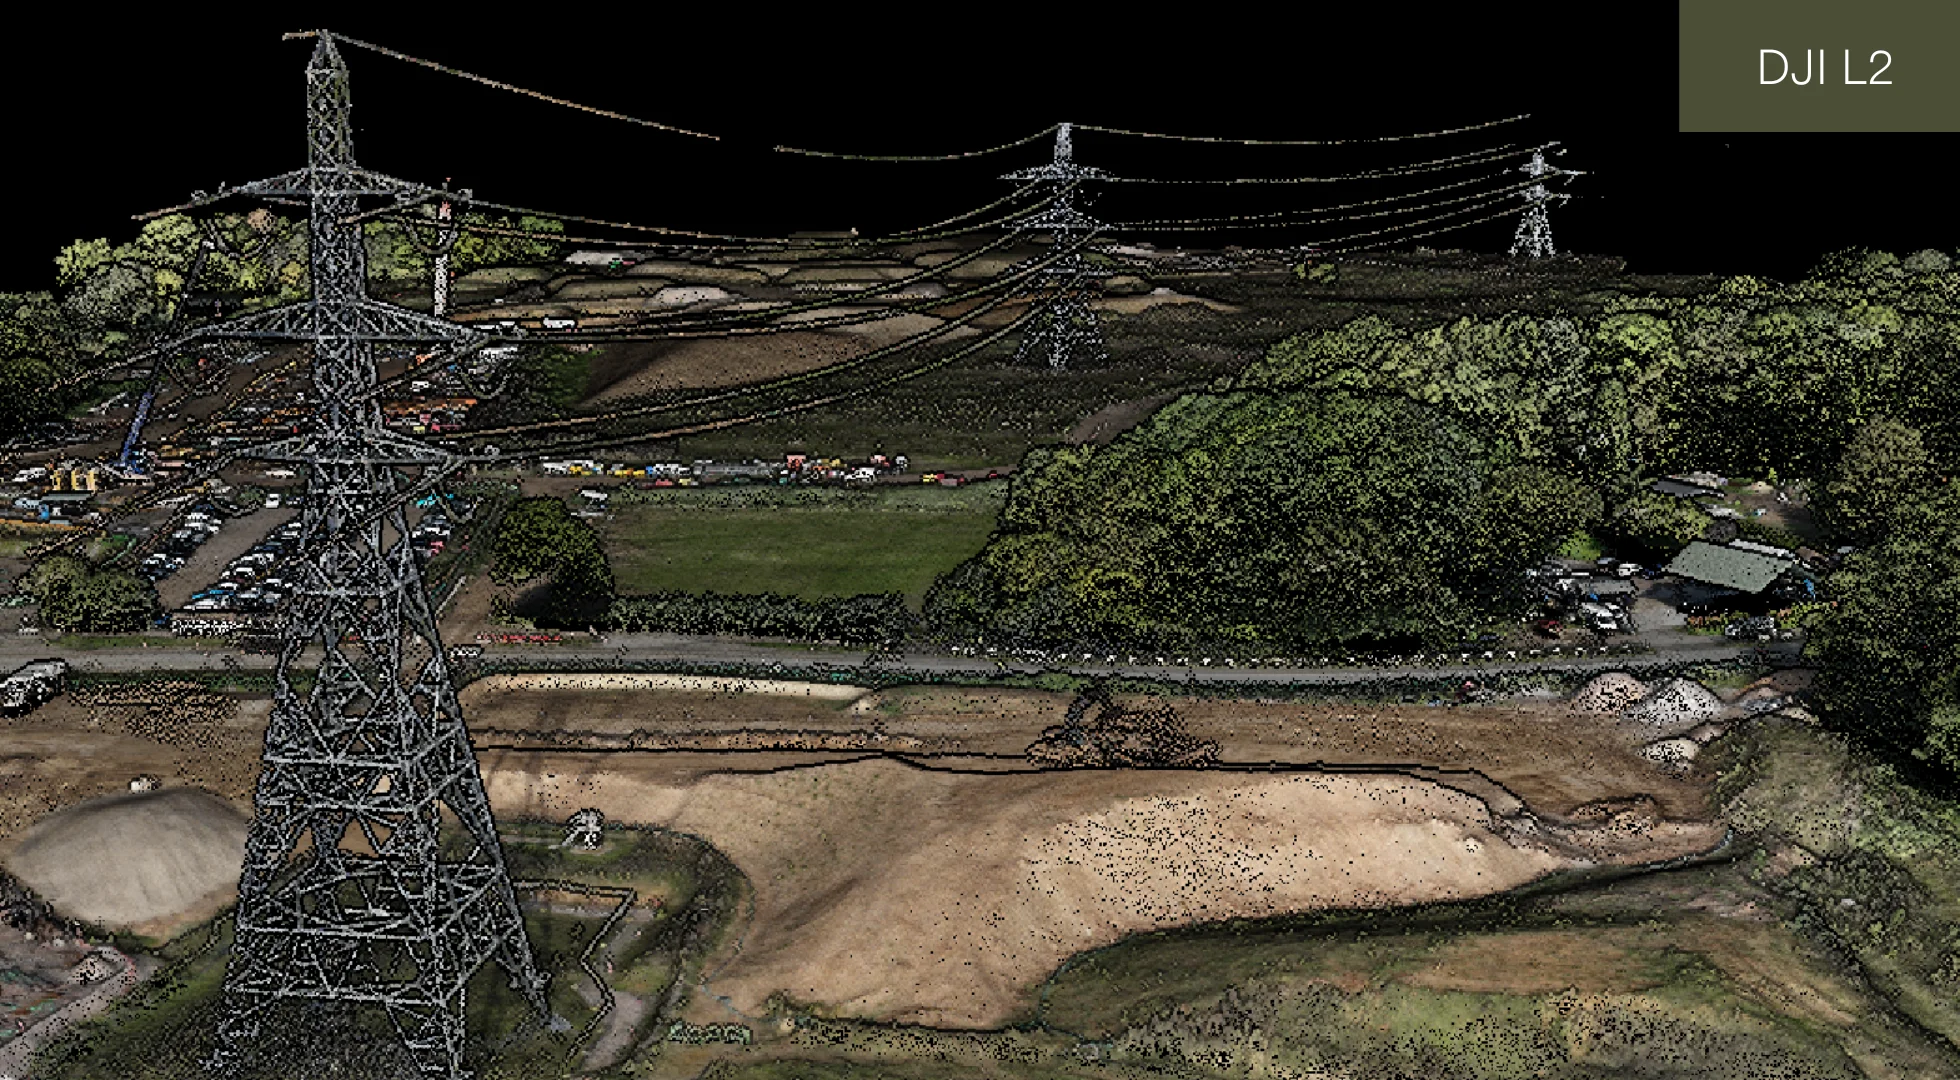
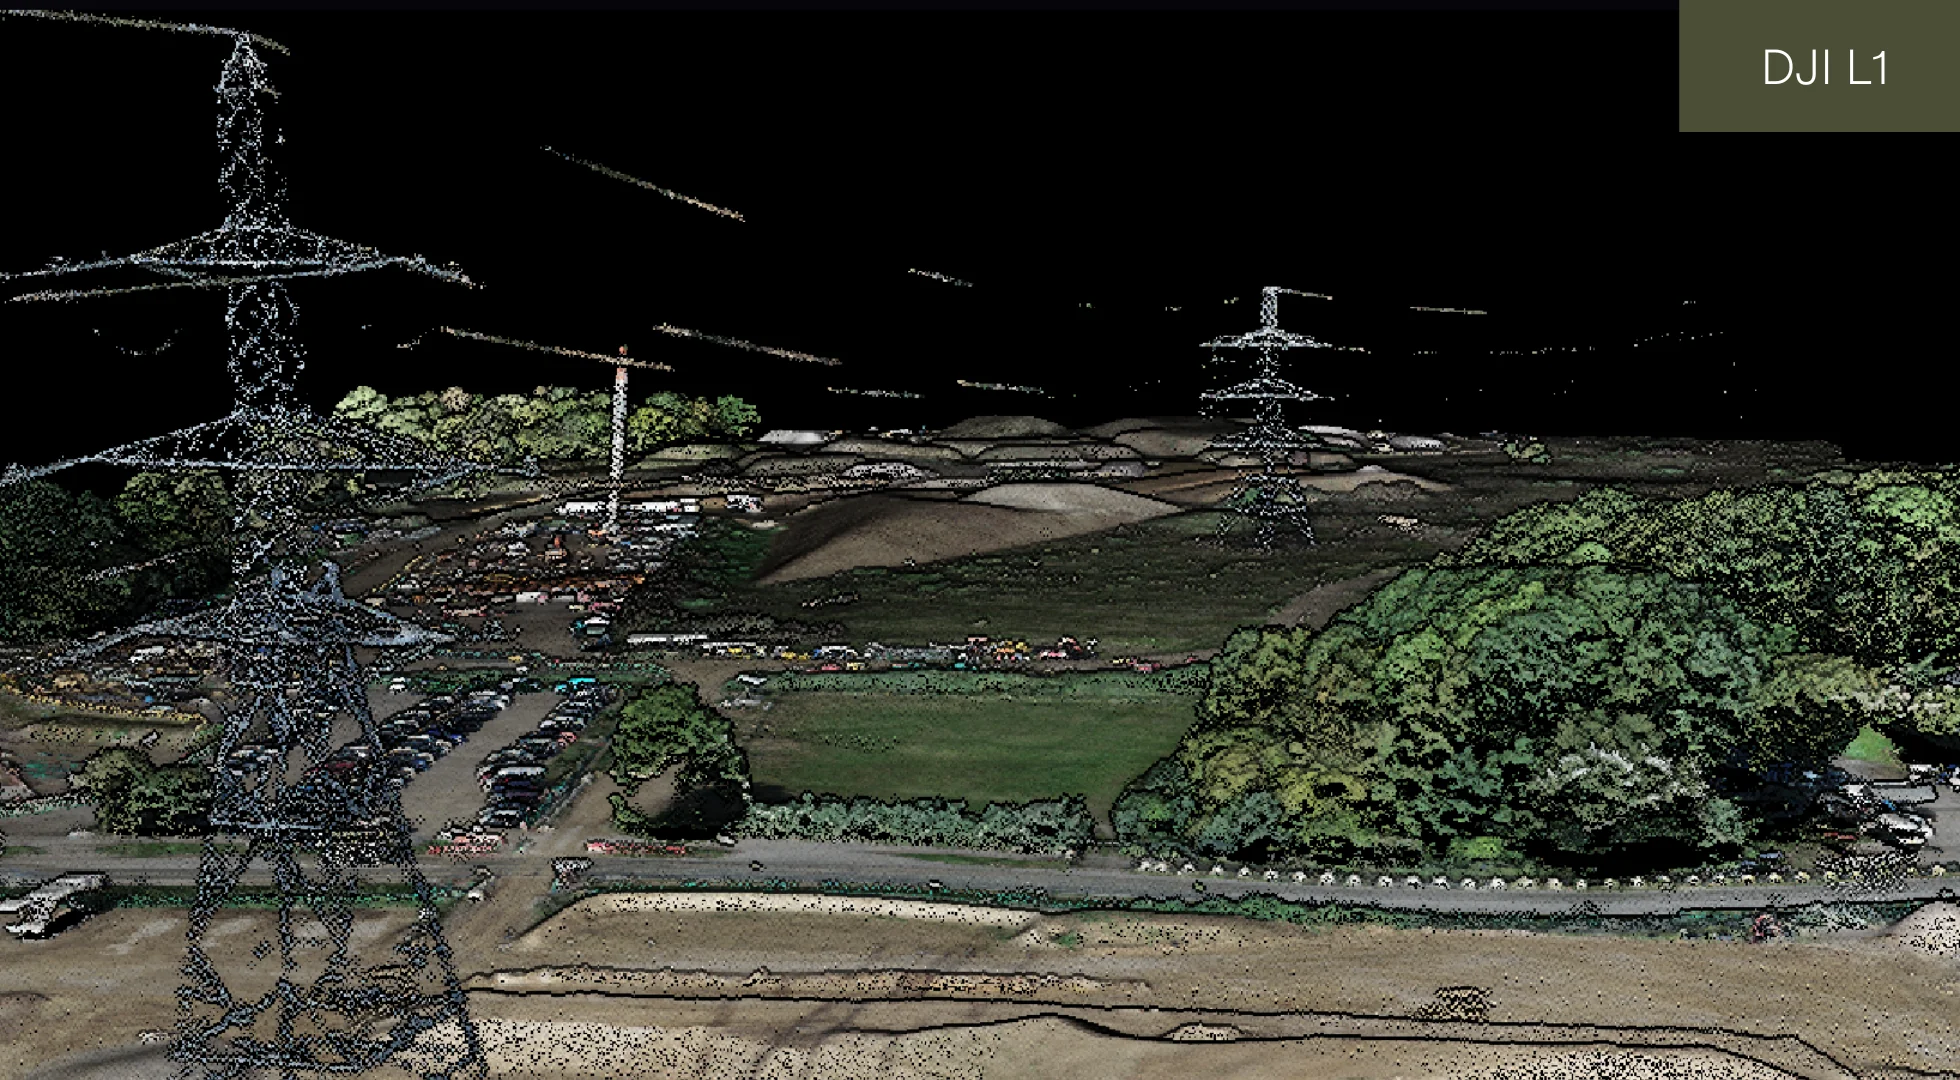
These two images showing identical cross-sections of power lines demonstrate L2’s advanced capabilities to detect small features on a survey site: in this case, power cables are recreated in greater detail.
And an accuracy report shows that the L2 can achieve an absolute vertical error of 44mm from a flight altitude of 50 meters, compared to the L1’s 51mm.
In this article we will take a look at the major updates to L2 and demonstrate how they can improve detection workflows compared to L1.
L2 vs L1: Key specs in brief
Before we dive into the datasets, let’s take a look at the specifications of L2 and L1.
| L2 | L1 | |
| Dimensions | 155 x 128 x 176 mm | 152 x 110 x 169 mm |
| Weight | 905±5 g | 930±10 g |
| Power | 28W (tipico) 58W (max) | 30W (tipico) 60W (max) |
| IP Rating | IP54 | IP54 |
| Supported drones | M300 RTK (richiede DJI RC Plus); M350 RTK | M300 RTK; M350 RTK |
| Range | 450m @ 50% reflectivity, 0klx; 250m @ 10% reflectivity, 100klx | 450m @ 80% reflectivity, 0 klx; 190m @ 10% reflectivity, 100 klx |
| Point Rate | Single return: max. 240,000 pts/s; Multiple returns: max. 1,200,000 pts/s | Single return: max. 240,000 pts/s; Multiple return: max. 480,000 pts/s |
| System accuracy (DJI Specs) | Orizzontale: 5 cm @ 150 m; Verticale: 4 cm @ 150 m. Entrambi a 150m altezza di volo, velocità di volo 15m/s | Orizzontale: 10 cm @ 50 m; Verticale: 5 cm @ 50 m. Entrambi a 50m altezza di volo, velocità di volo 10m/s |
| Real-time Point Cloud Colouring Modes | Reflectivity, Height, Distance, RGB | Reflectivity, Height, Distance, RGB |
| LiDAR: Maximum Returns Supported | 5 | 3 |
| LIDAR: Maximum Sampling Frequency | 240kHz for all modes, including Penta | 240 kHz (single/dual echo mode); 160 kHz (triple-echo mode) |
| LiDAR: Scan modes | Non-repetitive scanning pattern, Repetitive scanning pattern | Non-repetitive scanning pattern: Repetitive scanning pattern |
| RGB Mapping Camera: Sensor dimension & Pixels effectives | 4/3 inch; 20MP | 1 inch; 20MP |
| RGB Mapping Camera: Shutter Speed | Mechanical Shutter: 2-1/2000 s; Electronic Shutter: 2-1/8000 s | Mechanical Shutter Speed: 1/2000 – 8 s; Electronic Shutter Speed: 1/8000 – 8 s |
| RGB Mapping Camera: Video resolution | 4K @ 30fps | 4K @ 30fps |
| Suggested Speed Video Shooting | 15m/s | 8m/s to 12m/s |
| Pre-flight High-accuracy IMU Warm-up Required | No | Yes |
As the table shows, L1 and L2 are equipped with a LiDAR module, an RGB sensor for photogrammetry and point cloud coloring, and a high-precision IMU.
But the L2, unveiled by DJI on October 10, 2023, features some key improvements over the L1 (released in 2020), such as:
- Increased rate of return
- Higher sampling rate
- Smaller, more concentrated laser dots for denser point clouds
- Larger RGB mapping sensor
- Better detection rate: It can detect objects with 50% reflectivity, while L1 requires objects to have at least 80% reflectivity – from 450m.
- It does not require a 5-10 minute period for the IMU to warm up.
Test site one: Colne Valley Viaduct on phase one of HS2
JV Align (Bouygues Travaux Publics, Sir Robert McAlpine and VolkeFitzpatrick) is delivering the Central 1 (C1) section of Phase One HS2, including a 3.4km viaduct across the Colne Valley.
Partnered with Murphy Geospatial, a subcontractor of Align JV, to fly the L2 and L1 to the viaduct’s south embankment site.
Murphy says he would use L2 to:
- High density vegetation and where accurate soil levels are needed.
- Building/urban environments where there are very fine/small features that need to be recorded.
- Quantitative survey, especially where the material or soil has high reflective properties/characteristics.
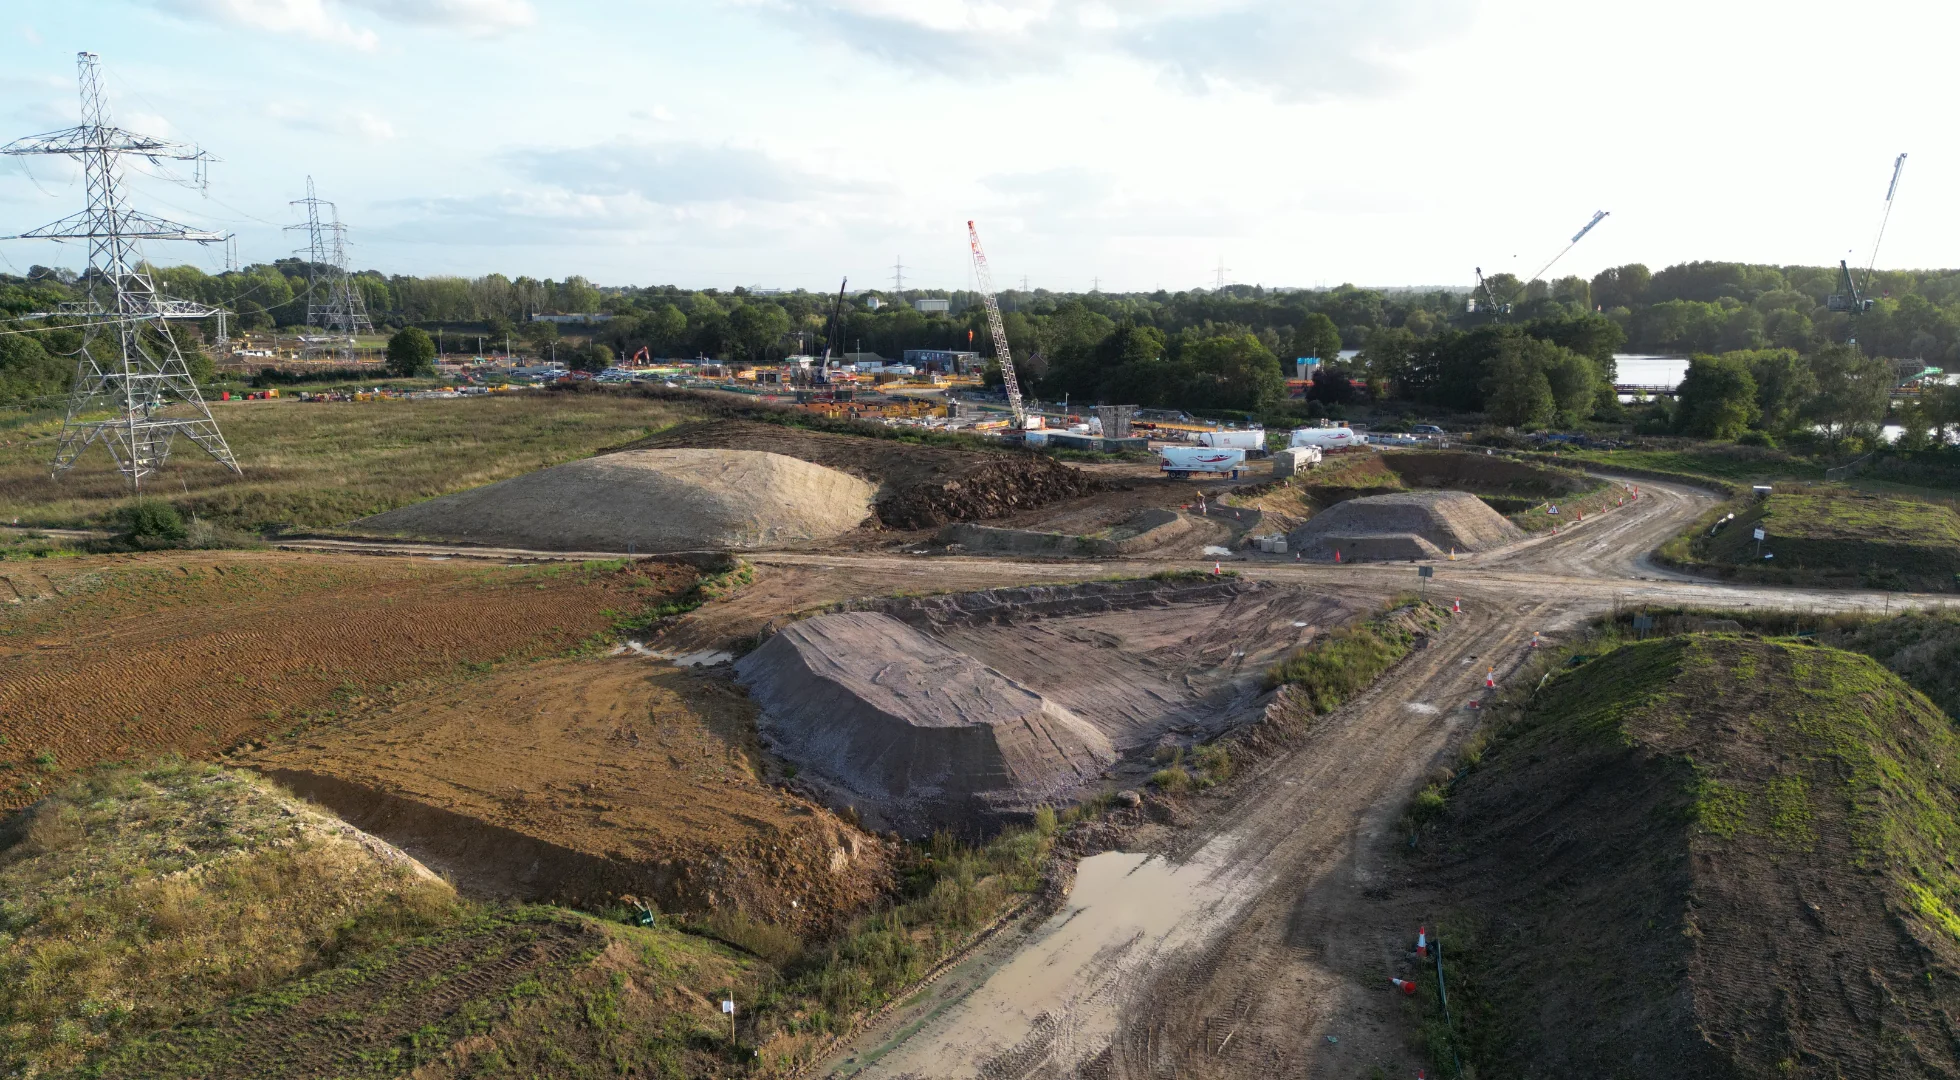
As such, it was an optimal test site, containing vegetation, power lines and supplies. It provided a good test bed for a LiDAR sensor.
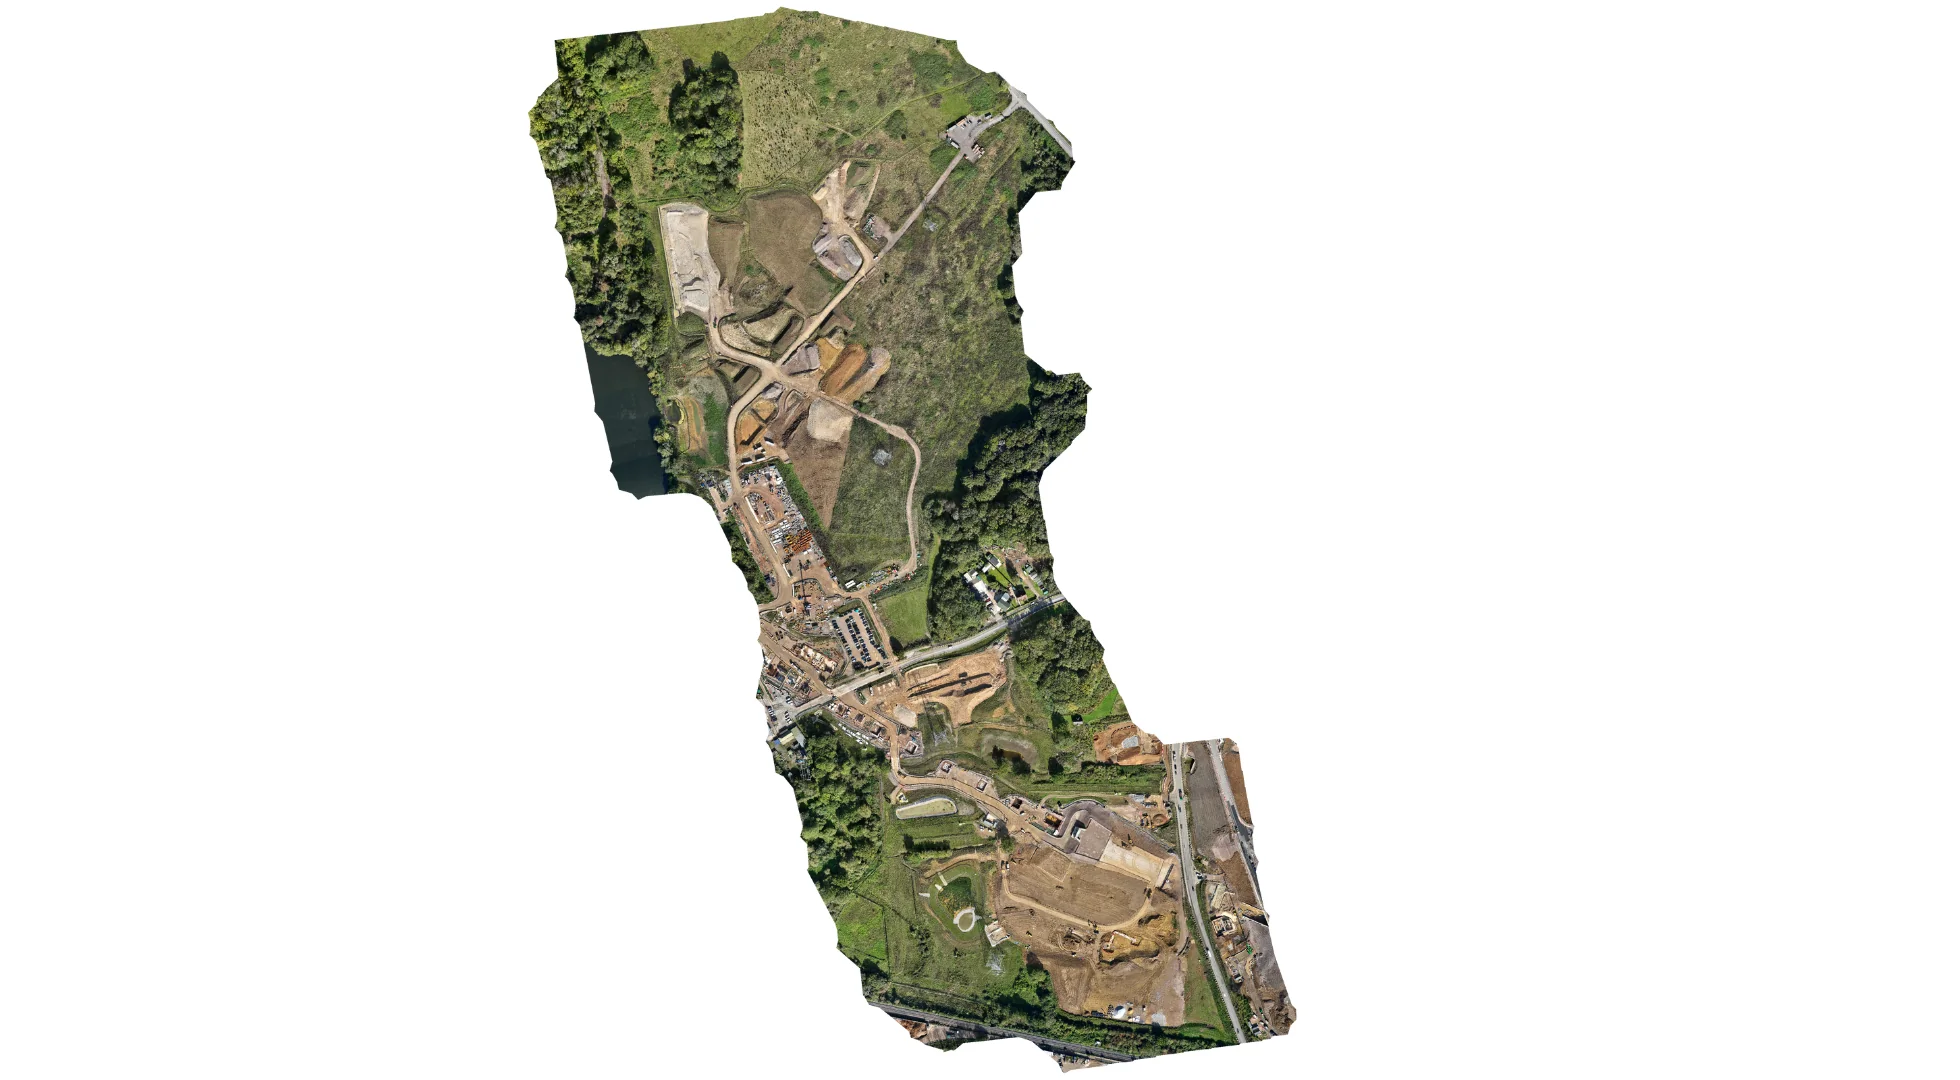
The site boundary is shown below, via a 2D orthomosaic produced using the L2’s RGB camera.
The following parameters were set for the flights:
| Parameter | L2 | L1 |
| Overlap | 50% | 50% |
| Velocità | 8m/s | 8m/s |
| Altezza | 100m | 100m |
| Return | Penta (5) | Triple (3) |
| Sampling Rate | 240khz | 160khz |
| Elevation Optimisation | Yes | Yes |
| Scanning Type | Repetitive | Repetitive |
| IMU Calibration | Yes | Yes |
| Mission Type | 2D Nadir | 2D Nadir |
| Flight Height | 100 metres | 100 metres |
| Photos | 334 | 325 |
| GSD | 2.69cm | 2.73cm |
| Mission Time | 24 min 27 sec Flight Time: 24 min 27 sec Pre-flight IMU warm-up: Not required | 32 min 50 sec Flight Time: 22 min 50 sec Pre-flight IMU warm-up: 10 minutes |
The parameters were identical, except for using the higher return rate and sample rate of L2.
It’s worth noting that the L2 can capture data at up to 15 m/s, for greater efficiency, but in this case we kept the speed at 8 m/s. Recommended parameters for L1 range from 8 m/s to 12 m/s, depending on the mission scenario.
The missions were conducted at a flight altitude of 100 meters. We were limited to this height due to the proximity of a local airport.
The L1 flew for 22 minutes and 50 seconds, while the L2 was slightly longer (24 minutes and 27 seconds), but this is attributed to the fact that the mission was flown with a Penta return speed.
Overall, the mission with the L2 was shorter as it did not require pre-flight IMU warm-up.
Power line inspection
LiDAR is particularly effective for power line inspection: the rapid emission of laser pulses and the ability to conduct multiple returns from a single laser pulse offer higher spatial resolution.
This helps capture more detailed information about complex structures such as power lines, including their shape and orientation, and better identify finer details.
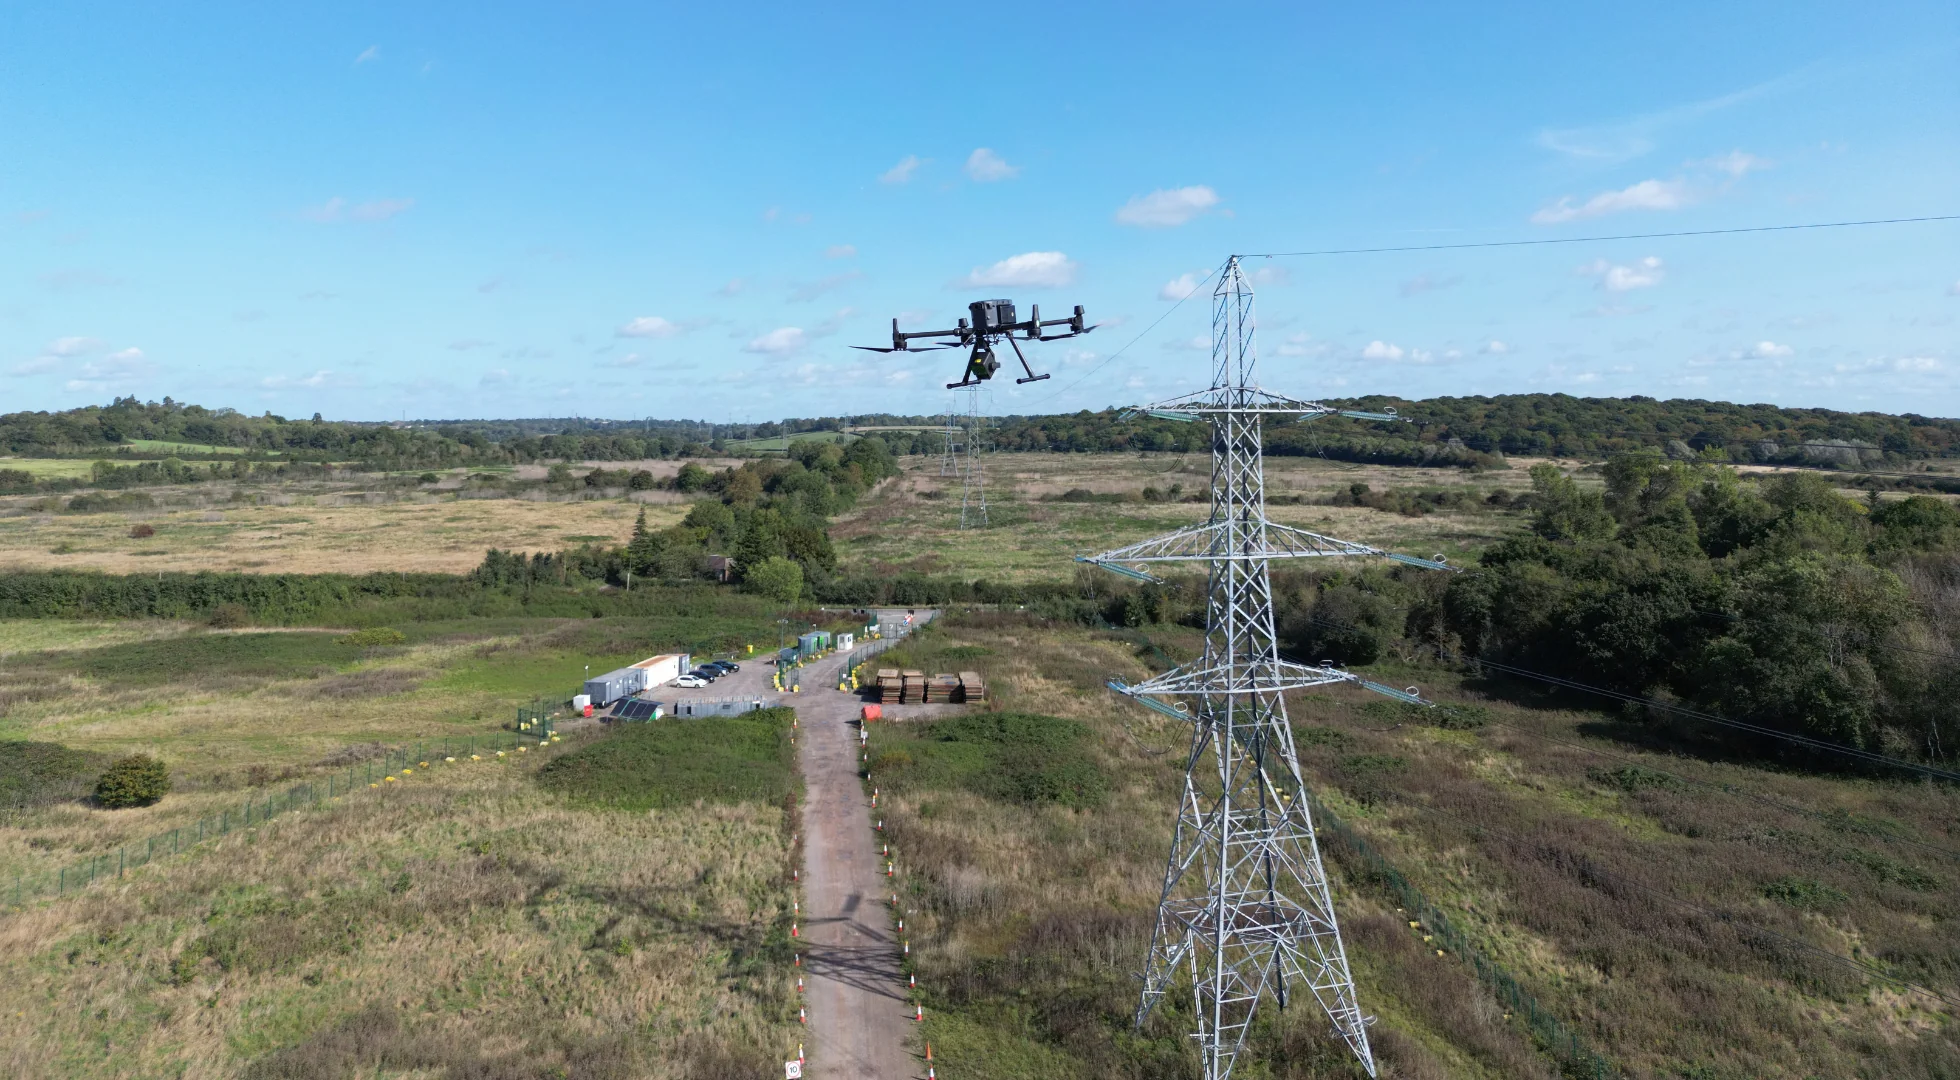
The following image shows the L2 mapping power lines on the HS2 site.
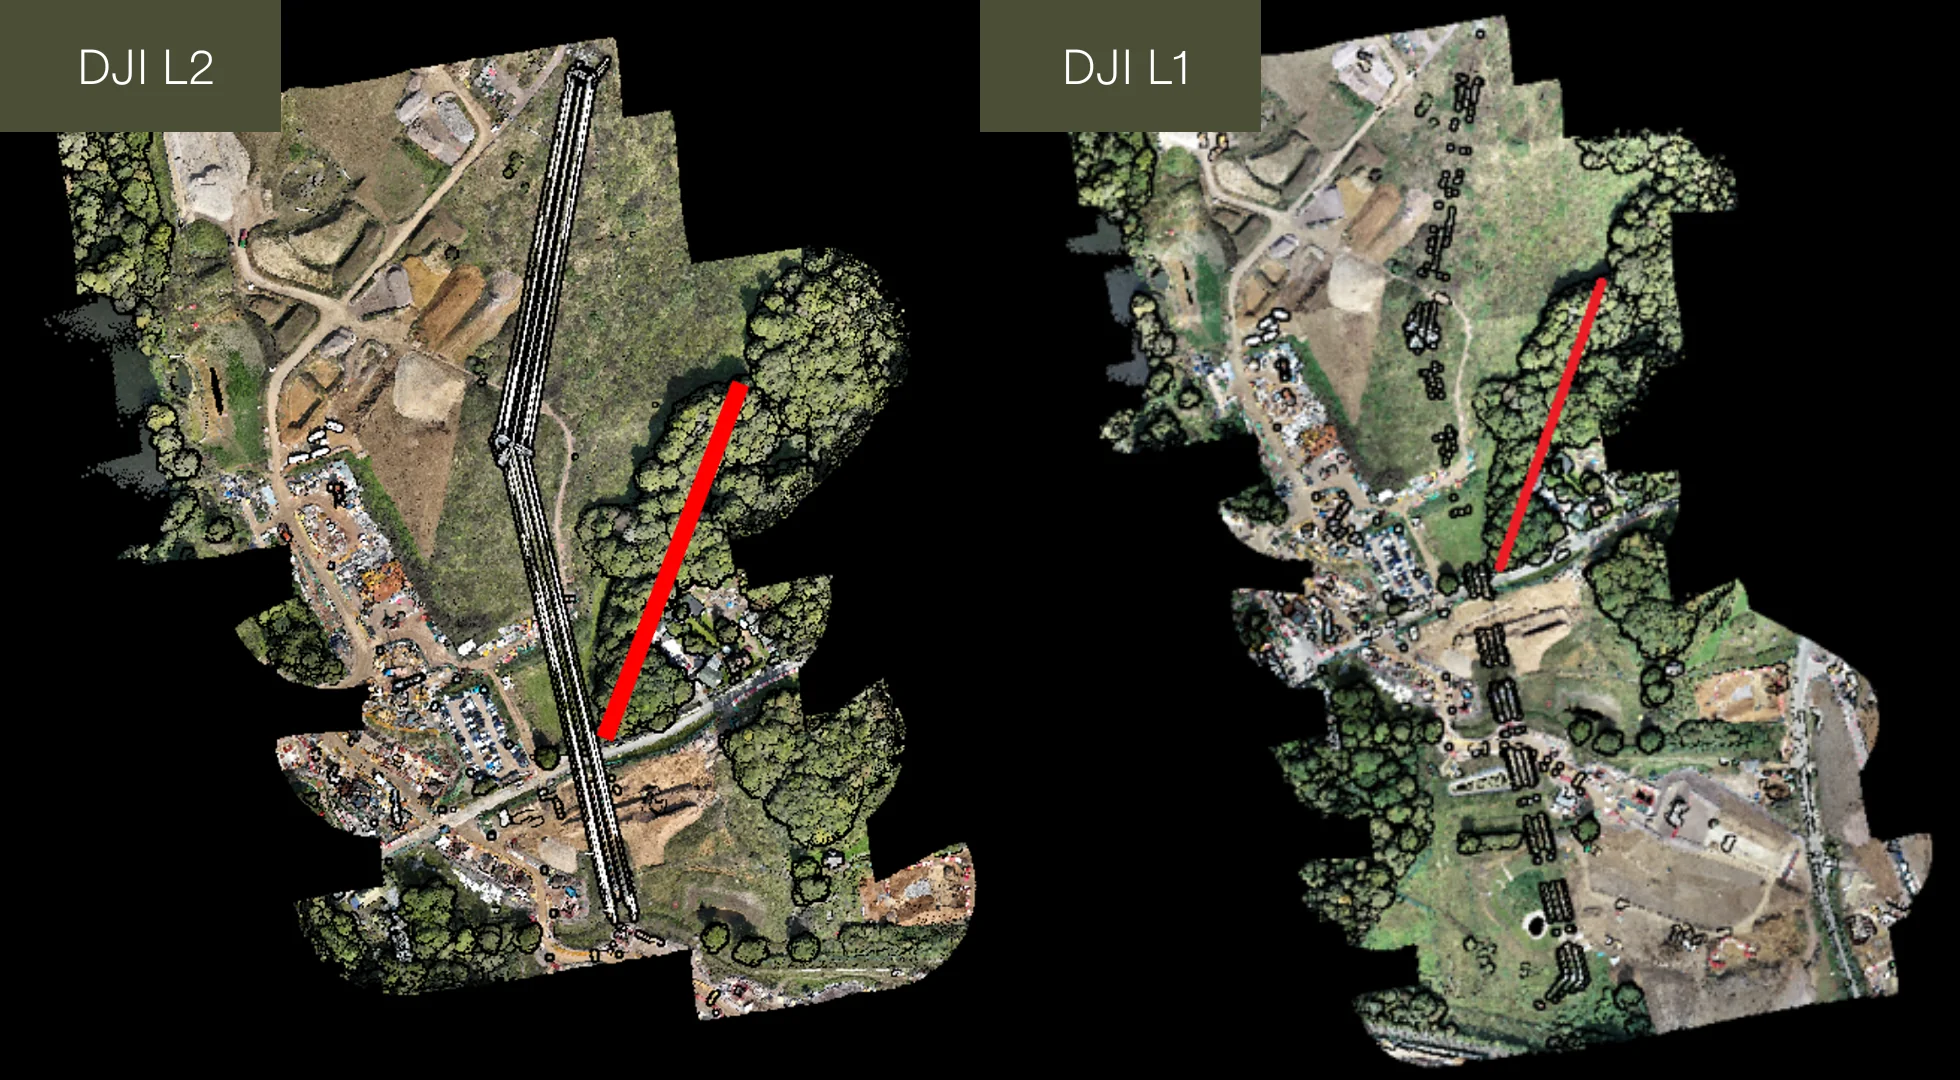
And when comparing the results between L2 and L1, it’s clear that L2 did a better job of detecting cables and transmission towers on site, as these two screenshots, taken from DJI Terra, show.
The greater level of detail in the L2 data is also evident in the top-down view below, using Terrasolid imagery. Notice how the power lines are more complete in the L2 dataset, but almost non-existent with L1.
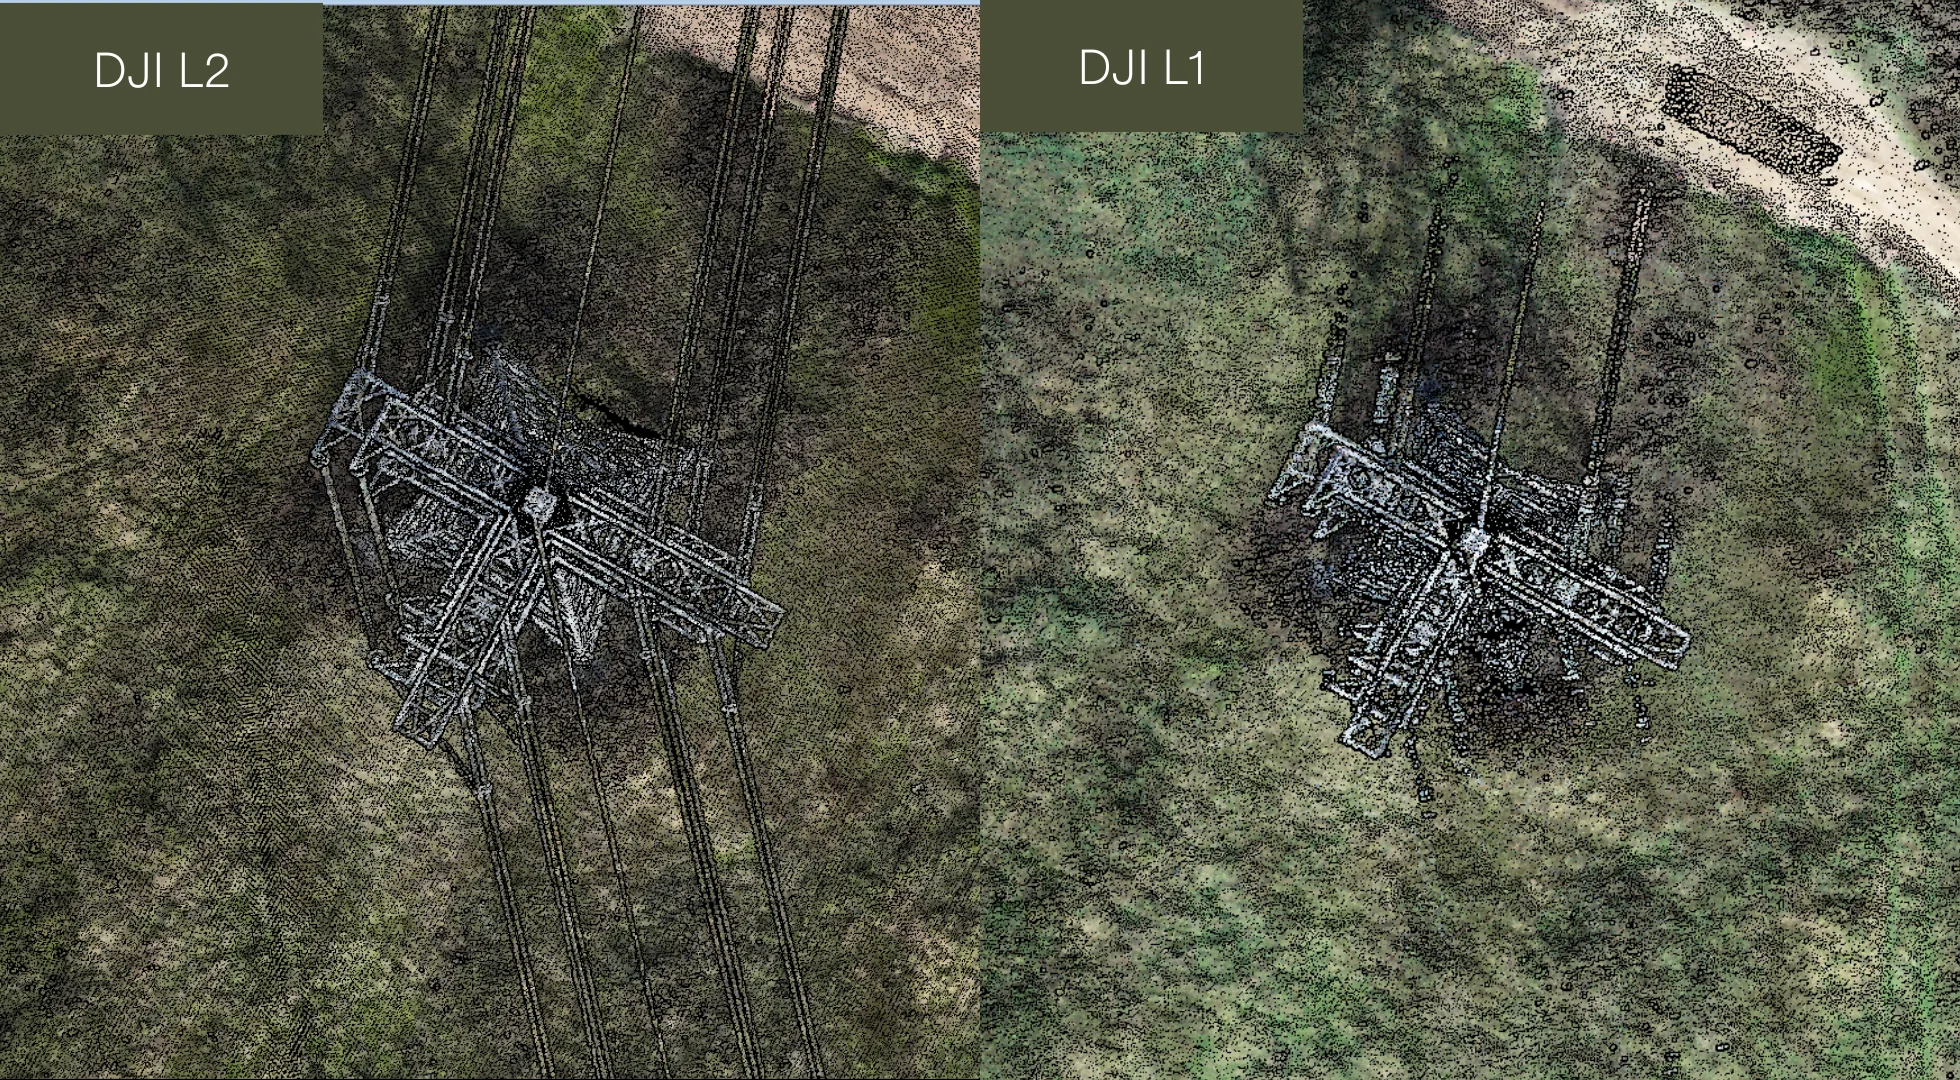
Terrasolid is a complementary software to DJI Terra. The initial data was processed in DJI Terra and then migrated to Terrasolid for further manipulation and analysis.
DTM
LiDAR is often considered better for generating digital terrain models (DTMs) than photogrammetry.
One of the main reasons for this is that LiDAR can penetrate dense vegetation and capture the ground surface, even under thick canopy. In contrast, photogrammetry may have difficulty capturing terrain due to obstruction of vegetation.
This is demonstrated in this graph showing the greater capabilities of LiDAR (pink) to penetrate tree canopy compared to photogrammetry (blue).

DTMs are the basis for creating detailed and accurate topographic maps, which provide essential elevation information and accurately represent the Earth’s natural surface in 2D.
They boast a range of use cases, such as flood risk assessment, natural resource management, precision agriculture, environmental impact assessments, disaster management and natural habitat modeling.
So, how do L2 and L1 fare when it comes to creating DTMs?
The graph below, taken from the HS2 website, shows that the L2 created a more robust and complete ground surface, compared to the L1.
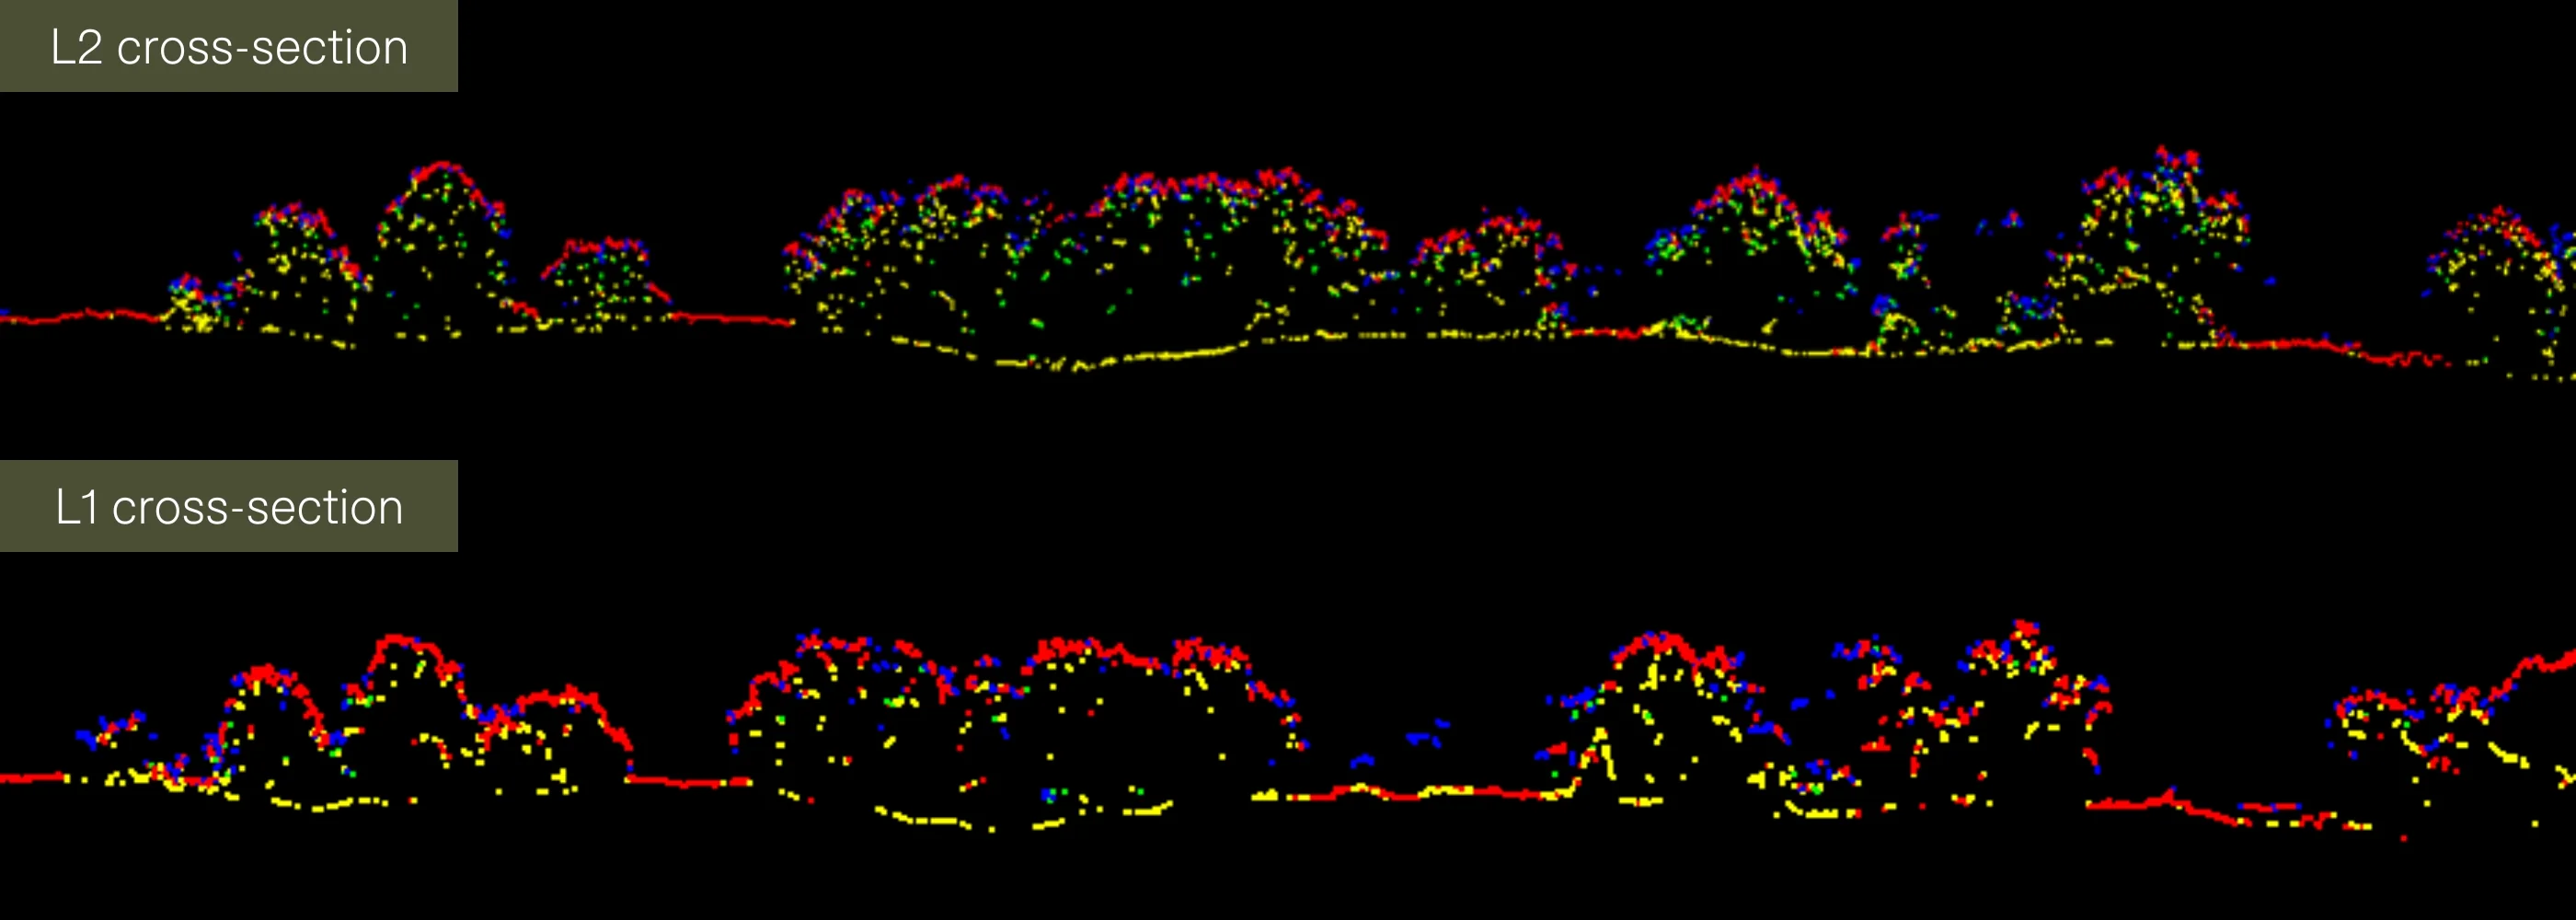
This allows for the creation of a better quality DTM. This is because when the point cloud is rasterized to create the DTM there are fewer gaps in the data. The L2 DTM is much more complete with fewer areas where there is no recorded data to base the surface on.
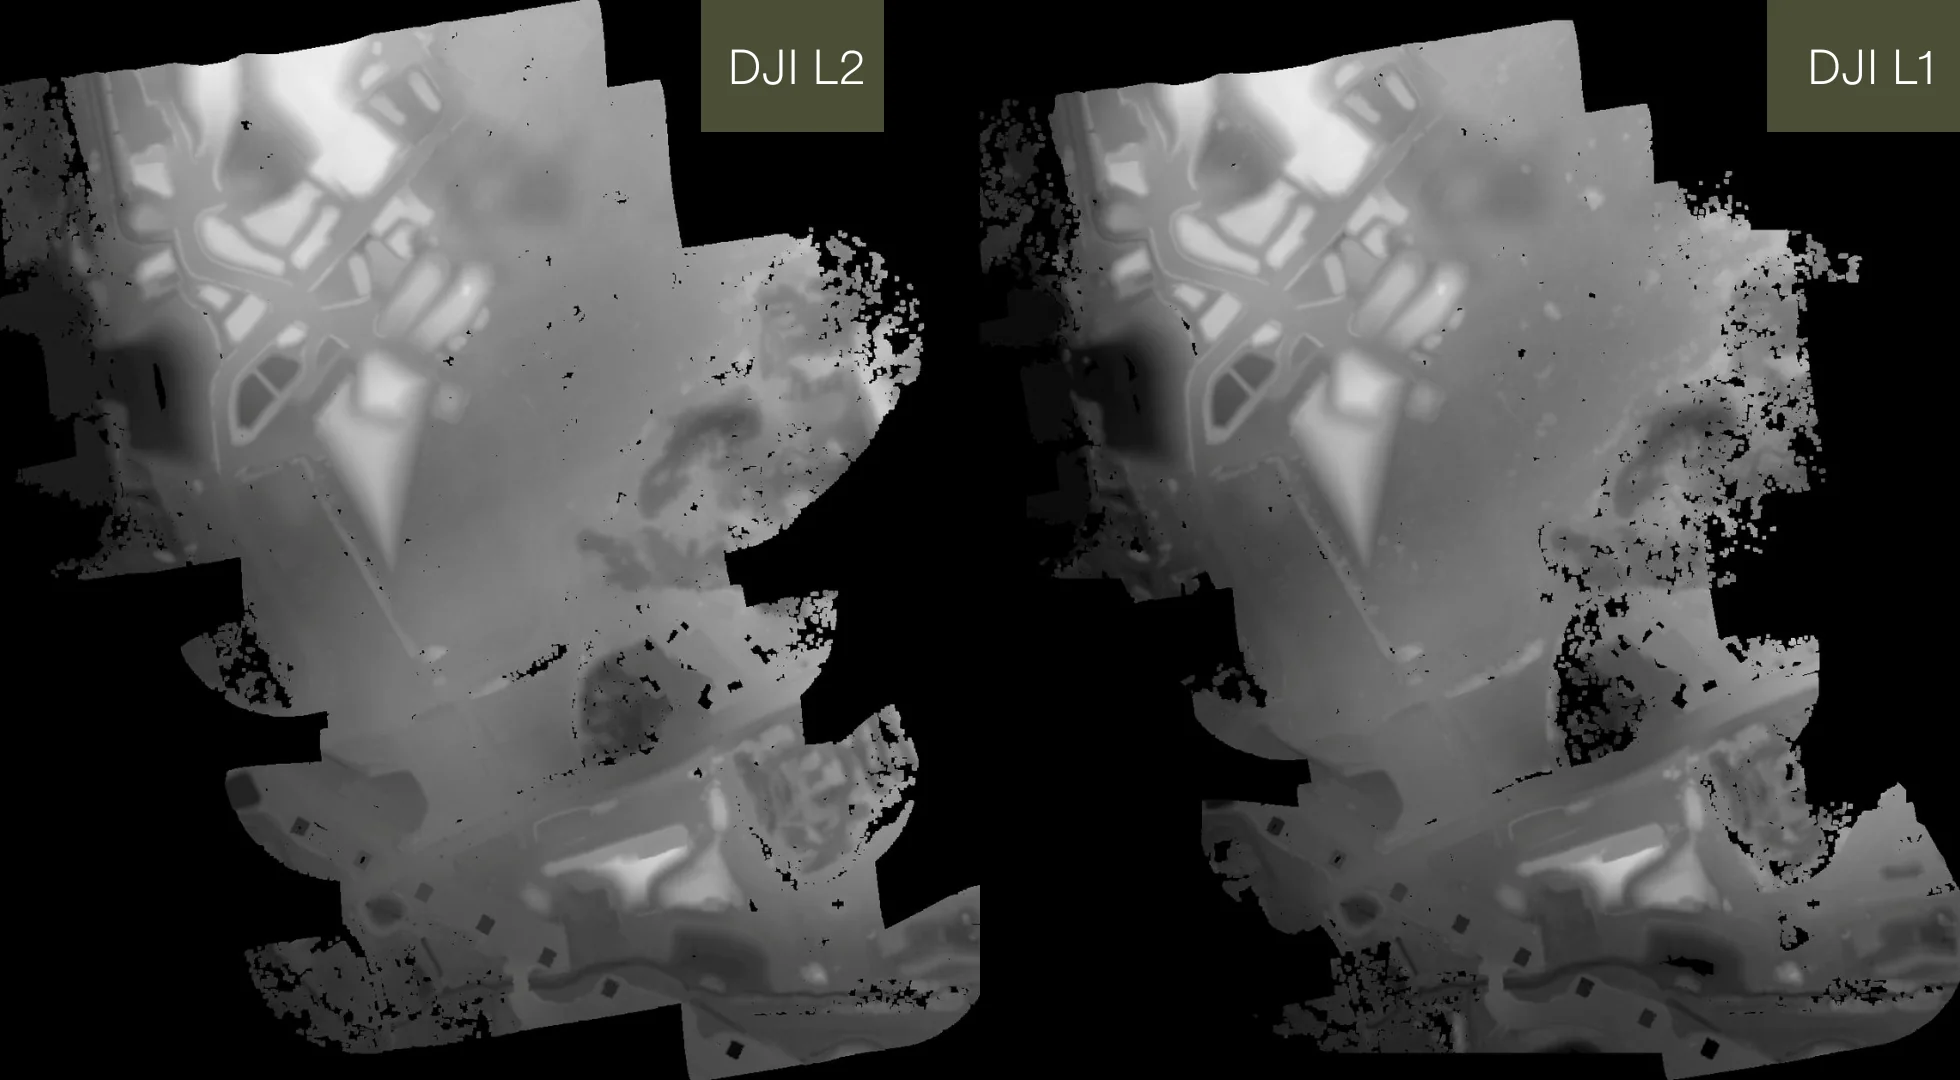
This is aided by L2’s higher sampling rate and throughput levels.
Vertical cross sections are shown above showing the return pulse data.
The images below show the flight path over the vegetation area. Incidentally, note also how the power lines are more complete in the L2 view, compared to the L1.
Impressed with the L2
After seeing the results, Pedro de Gouveia, chief UAV pilot at Murphy Geospatial, praised the L2’s capabilities.
He said: “I am very impressed with the quality of the point cloud and the density perspective that comes from L2 compared to L1.
“It’s definitely a big step up from the previous sensor, so we’re pretty excited about it.
“As we saw with the L2 data, the extra detail in finer features like power lines and more robust penetration of vegetation produces better quality results.
“We are very interested in the increase in data quality compared to the L1 and the greater efficiency of use: an example is that the L2 does not require an IMU warm-up before use.”
Test Site Two: Komatsu (Intelligent Construction)
We conducted a precision test at our second site, at Komatsu UK (Smart Construction), where heliguy™ held the first official demonstration of the DJI Dock in the UK.
The aim was to evaluate the vertical accuracy of both sensors, compared to some ground controls.
The detection site is depicted below, using a 2D orthomosaic created with data captured by the L2’s RGB camera.
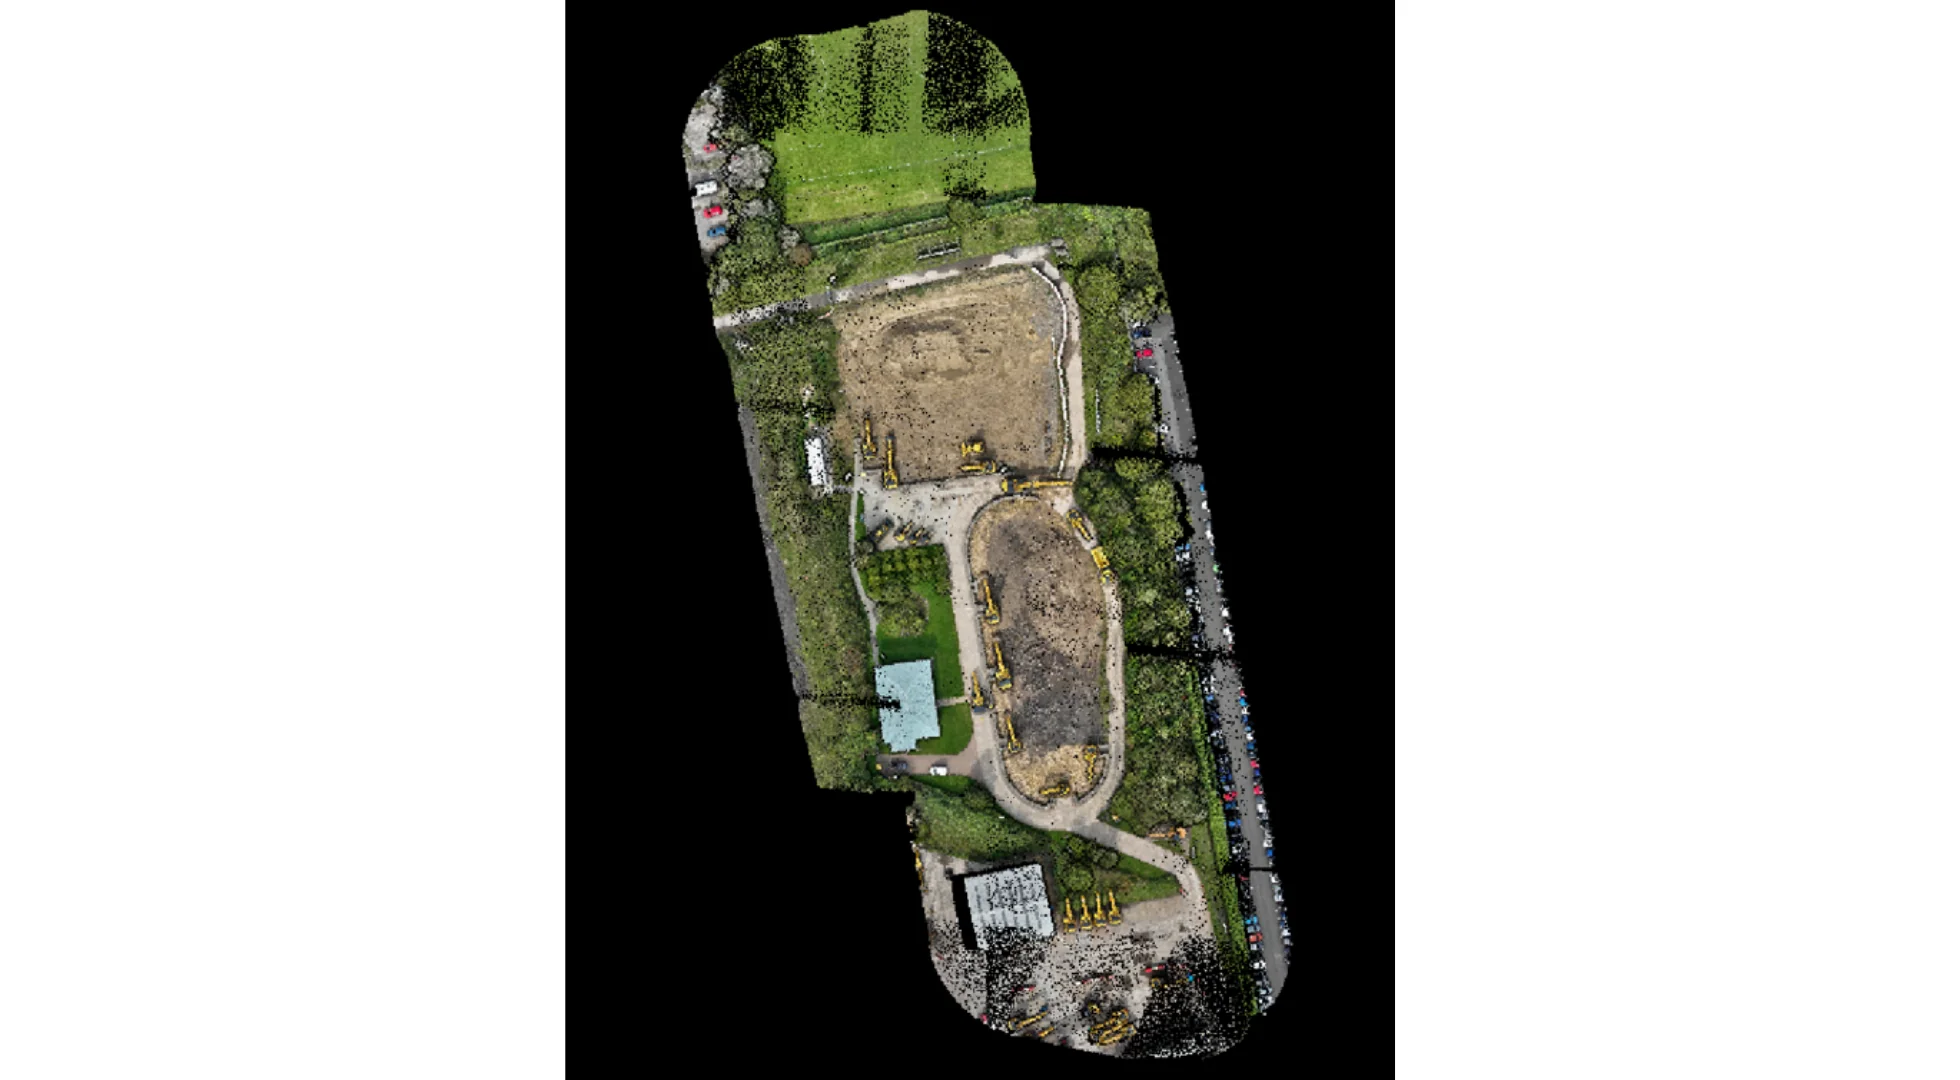
The flight was conducted at an altitude of 50 meters using the RTK network.
The accuracy was compared with 11 control points, located around the site, as shown in the image below.
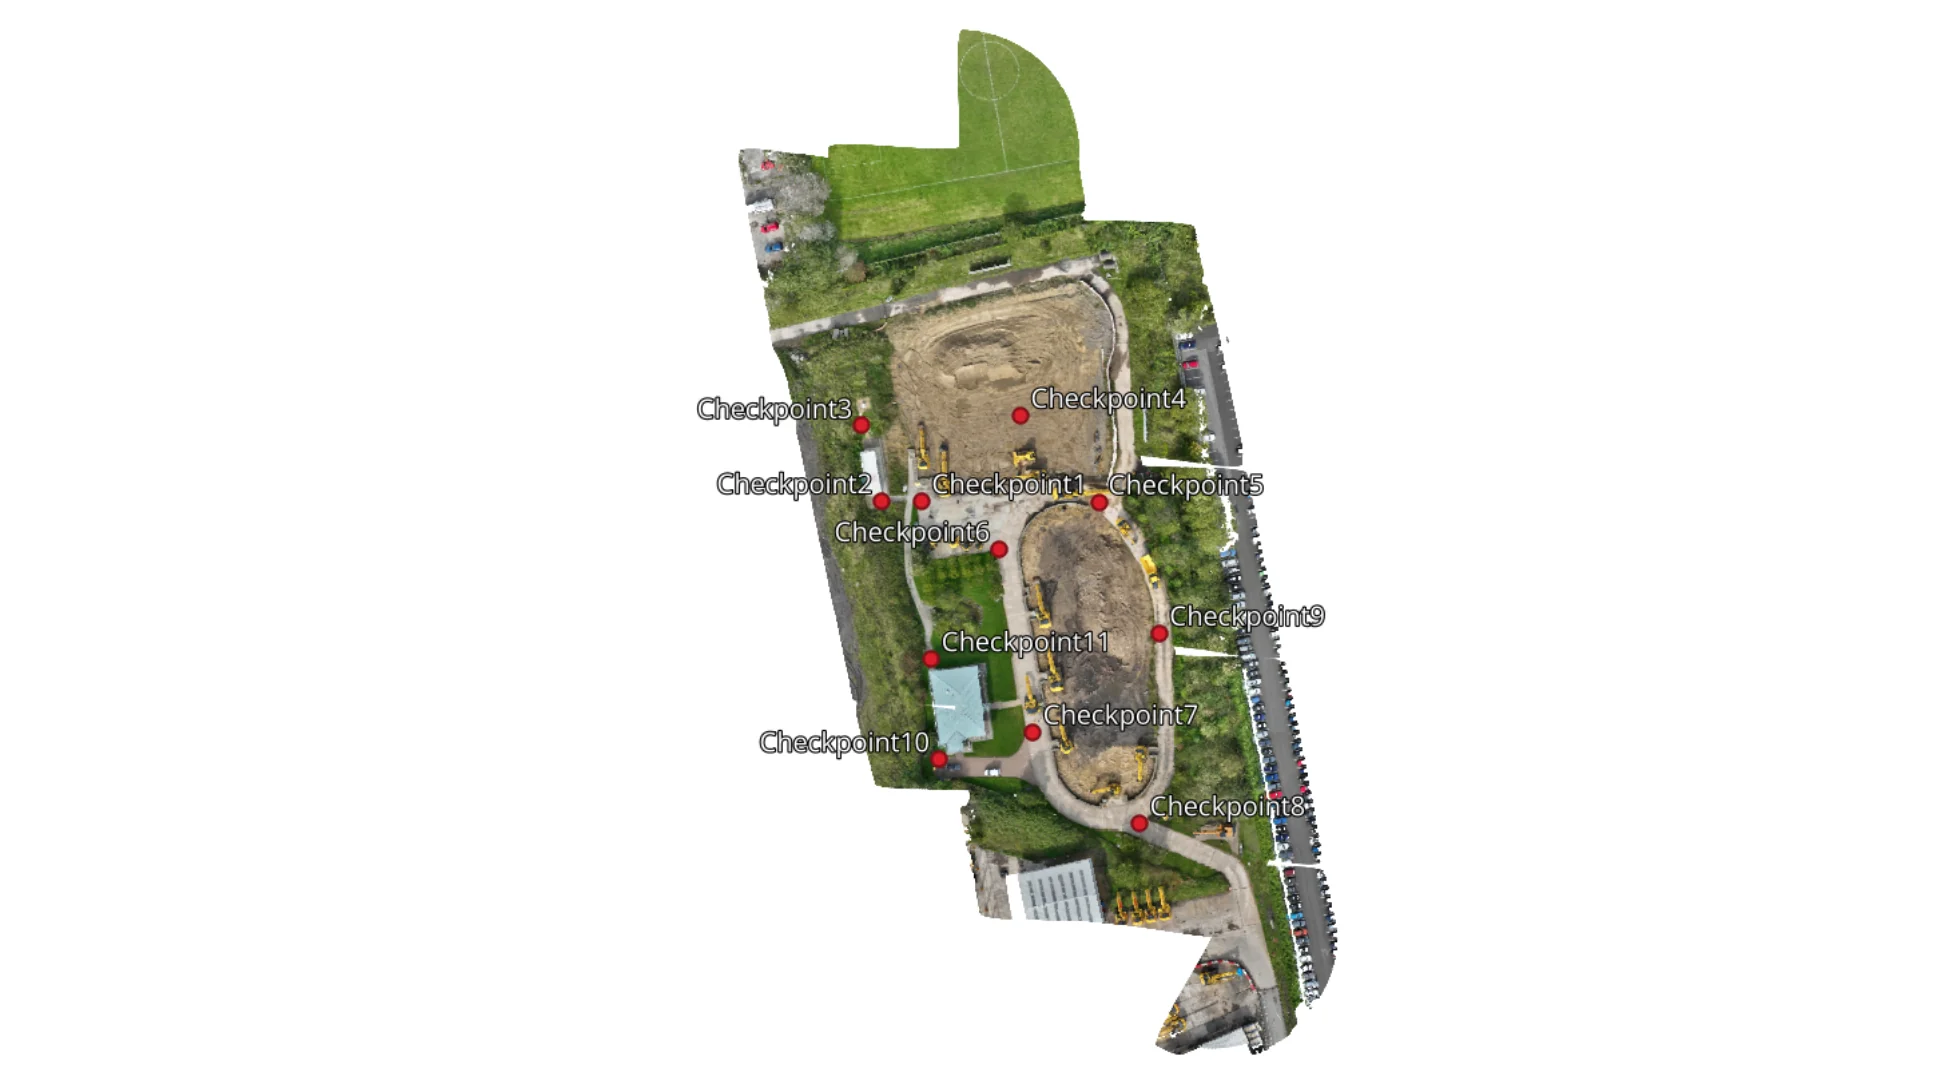
Data was acquired with Emlid RX using kinematic GNSS.
Checkpoints were collected relative to the OSGB36 British National Grid horizontal coordinate system and the Ordnance Datum Newlyn vertical coordinate system.
LiDAR data was transformed and compared to elevations using DJI Terra software. (repetitive)
Accuracy results are shown in the following tables.
L2 – Accuracy Table
| lD | X/E | Y/N | Z/U | Reconstruction Altitude | Altitude Difference | Reflectivity | DEM Residual |
| Checkpoint 1 | 426988.744 | 555507.879 | 29.574 | 29.510955 | -0.063045 | 44.176471 | -0.064533 |
| Checkpoint 2 | 426977.154 | 555507.738 | 32.386 | 32.332125 | -0.053875 | 68 | -0.053776 |
| Checkpoint 3 | 426971.714 | 555529.27 | 32.334 | 32.265565 | -0.068435 | 60.888889 | -0.064175 |
| Checkpoint 4 | 427016.95 | 555532.088 | 29.268 | 29.248312 | -0.019688 | 31.076923 | -0.01939 |
| Checkpoint 5 | 427039.261 | 555507.449 | 29.547 | 29.517893 | -0.029107 | 51 | -0.006884 |
| Checkpoint 6 | 427010.67 | 555494.035 | 29.465 | 29.437909 | -0.027091 | 52.428571 | -0.032742 |
| Checkpoint 7 | 427020.45 | 555441.956 | 29.419 | 29.390565 | -0.028435 | 47.05 | -0.03006 |
| Checkpoint 8 | 427050.895 | 555415.93 | 29.422 | 29.386423 | -0.035577 | 50.571429 | -0.042391 |
| Checkpoint 9 | 427056.486 | 555470.066 | 31.769 | 31.736009 | -0.032991 | 38.363636 | -0.052366 |
| Checkpoint 10 | 426993.7 | 555434.146 | 31.321 | 31.263169 | -0.057831 | 33 | -0.057875 |
| Checkpoint 11 | 426991.519 | 555462.74 | 31.103 | 31.032755 | -0.070245 | 42.333333 | -0.086014 |
L1 – Accuracy Table
| ID | X/E | Y/N | Z/U | Reconstruction Altitude | Altitude Difference | Reflectivity | DEM Residual |
| Checkpoint 1 | 426988.744 | 555507.879 | 29.574 | 29.613559 | 0.039559 | 40.875 | 0.037683 |
| Checkpoint 2 | 426977.154 | 555507.738 | 32.386 | 32.433613 | 0.047613 | 57 | 0.044113 |
| Checkpoint 3 | 426971.714 | 555529.27 | 32.334 | 32.38752 | 0.05352 | 59 | 0.052116 |
| Checkpoint 4 | 427016.95 | 555532.088 | 29.268 | 29.33932 | 0.07132 | 29.477273 | 0.068321 |
| Checkpoint 5 | 427039.261 | 555507.449 | 29.547 | 29.594818 | 0.047818 | 35 | 0.060699 |
| Checkpoint 6 | 427010.67 | 555494.035 | 29.465 | 29.511275 | 0.046275 | 38.217391 | 0.040709 |
| Checkpoint 7 | 427020.45 | 555441.956 | 29.419 | 29.464285 | 0.045285 | 28.833333 | 0.041271 |
| Checkpoint 8 | 427050.895 | 555415.93 | 29.422 | 29.476193 | 0.054193 | 39.859155 | 0.053391 |
| Checkpoint 9 | 427056.486 | 555470.066 | 31.769 | 31.81791 | 0.04891 | 32.4 | 0.038929 |
| Checkpoint 10 | 426993.7 | 555434.146 | 31.321 | 31.367136 | 0.046136 | 16.823529 | 0.038454 |
| Checkpoint 11 | 426991.519 | 555462.74 | 31.103 | 31.032755 | 0.070319 | 20.615385 | 0.077148 |
To get our absolute vertical error, we added the Altitude Difference fields and divided them by 11.
Using DJI Terra output, this gave an absolute vertical error of 0.044 (44mm) for L2 and 0.051 (51mm) for L1.
This particular survey did not use black and white control markers that would be visible on LiDAR data. To evaluate XY planimetric accuracy, signal markers can be imported into Terrasolid software for comparison.
Accuracy was the main test at the Komatsu site. But it’s also worth considering the difference in the resulting RGB point cloud views between the two.
Once again, the L2 created a more robust colored point cloud.
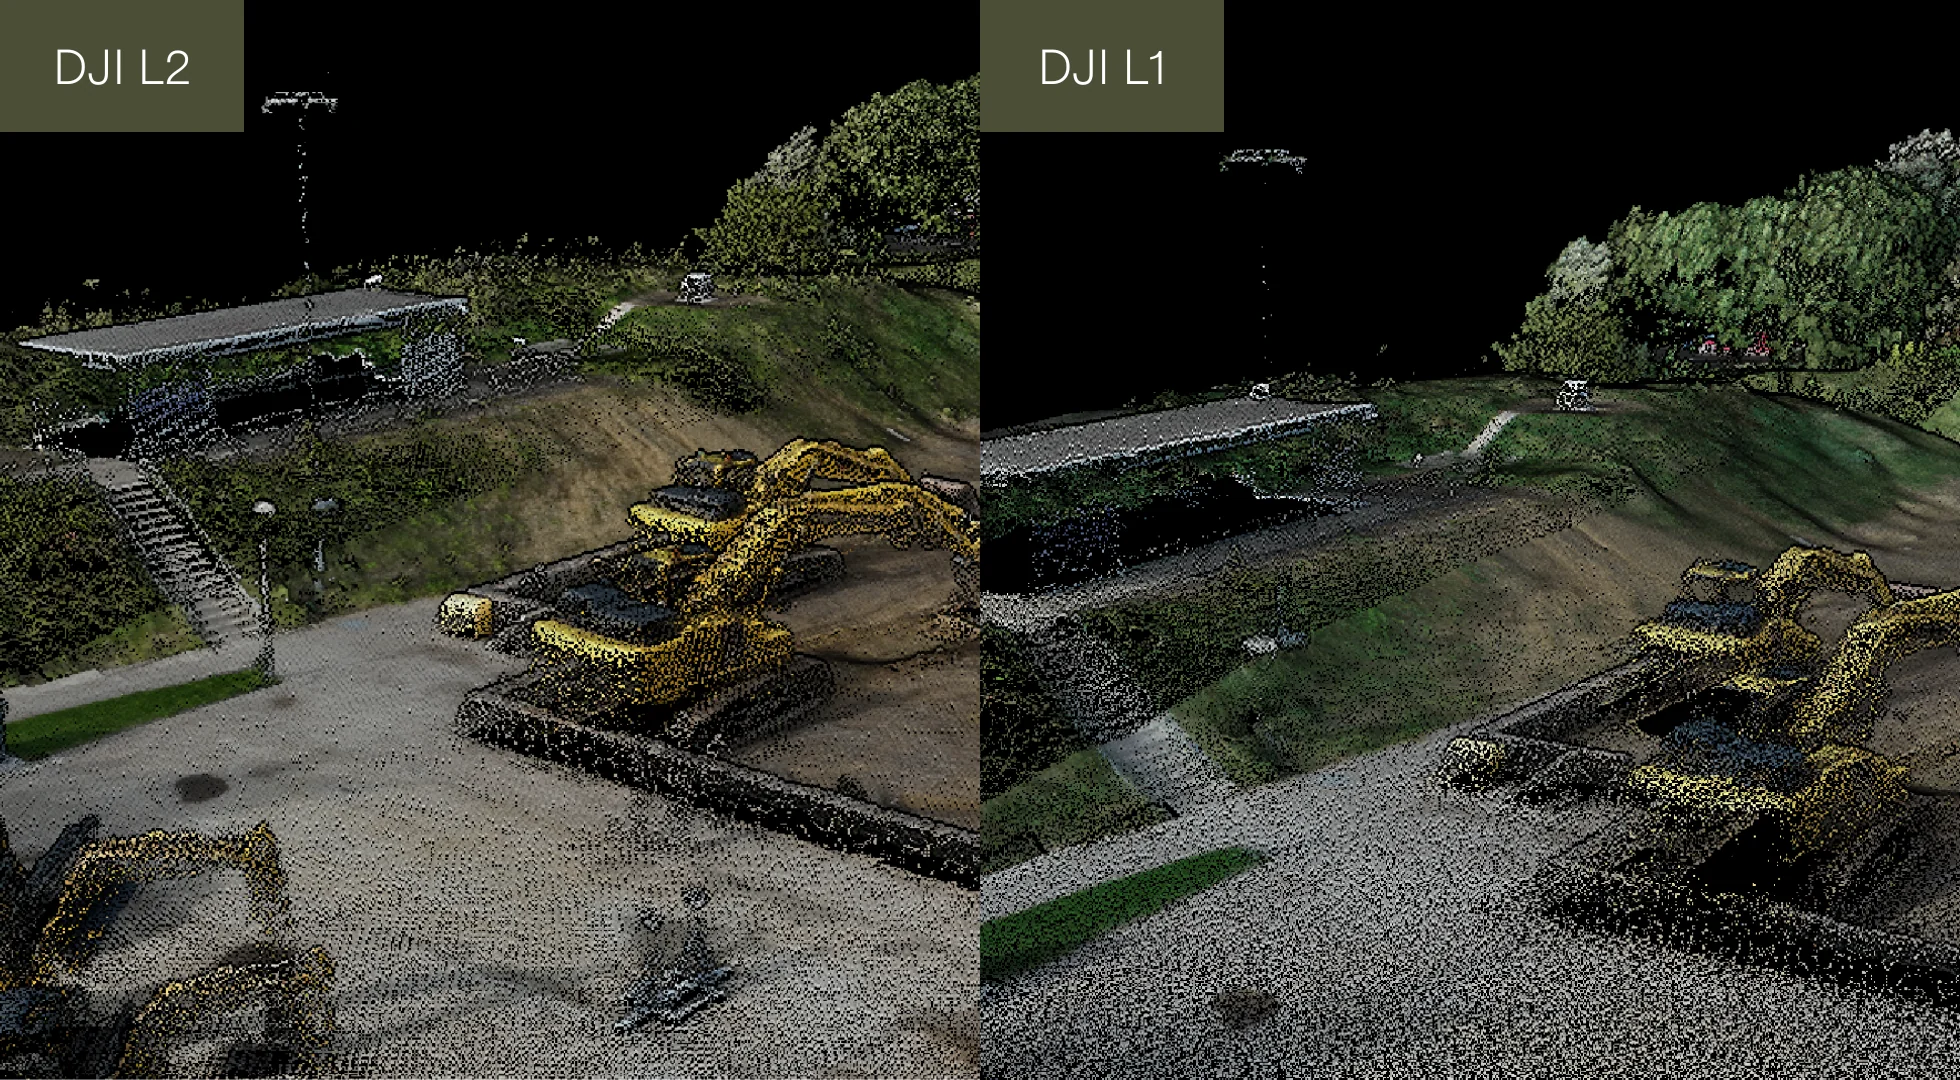
For example, in the L2 graph:
- The steps are more defined;
- The projector in the center of the image is more robust;
- There is a light column to the left of the image. This column is missing in the L1 dataset;
- The wall is more complete and texture is added to the top of the wall;
- Diggers are more complete and have extra detail.
Summary
Released in 2020, the L1 was a revolutionary sensor: it offers a plug and play LiDAR and photogrammetric solution at an affordable price.
Now, L2 is here and offers some significant advancements that will improve survey accuracy, efficiency and point cloud generation.
